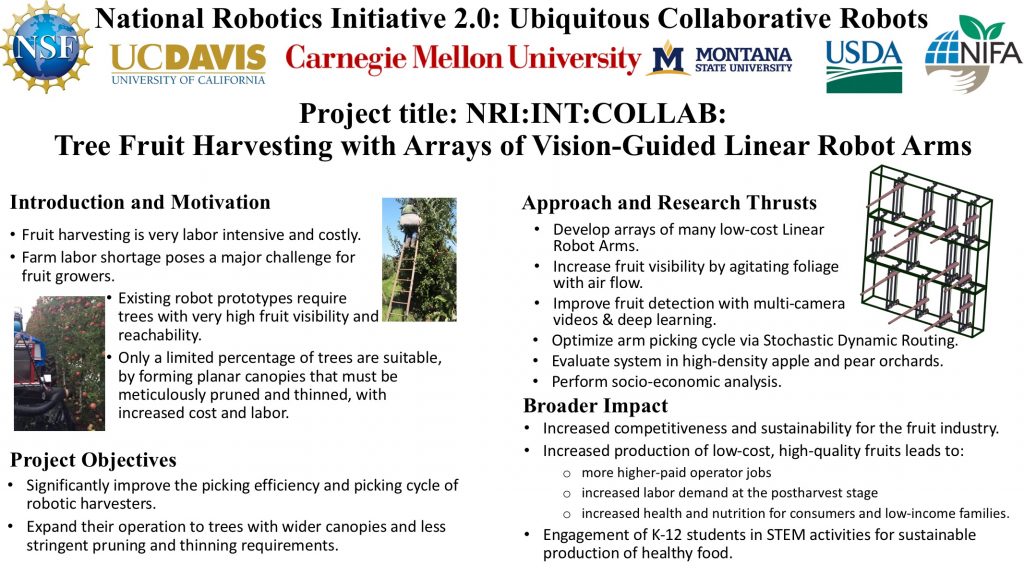
Tree fruit harvesting with arrays of vision-guided linear robot arms
Selective robotic picking has been demonstrated, but machines are still too slow, and many of them only work in canopies that have been pruned into a very thin fruiting wall. This project studies harvesters built from many low-cost linear arms, with shared vision, airflow to open the canopy, and scheduling that balances the picking cycle across the arms. The target crops are high-density apples and pears, including trees that are wider and less strictly pruned than a planar wall.